01 · PLATFORM
OpenIPC at its core
A familiar open-source camera platform for configuration, firmware work and project-specific integration.
Compact OpenIPC-based digital video transmission hardware designed for FPV aircraft, UAV development and embedded vision projects. Video transmission and bidirectional MAVLink data integration are designed to work together in compatible configurations.
A product platform for developers who need access to hardware interfaces, configuration and integration—not just a closed video transmitter.
01 · PLATFORM
A familiar open-source camera platform for configuration, firmware work and project-specific integration.
02 · IMAGING
Separate M12 lens camera module; supported CMOS options vary by order and firmware.
03 · WIRELESS
Two IPEX antenna connections and configurable power options subject to local radio regulations.
04 · POWER
Documented 9–22 V supply input with a combined power and serial interface.
05 · THERMAL
Aluminum fins and an active fan, with mounting space and airflow to be considered.
06 · INTEGRATION
UART enables MAVLink connections to a flight controller; Ethernet supports local configuration and testing.
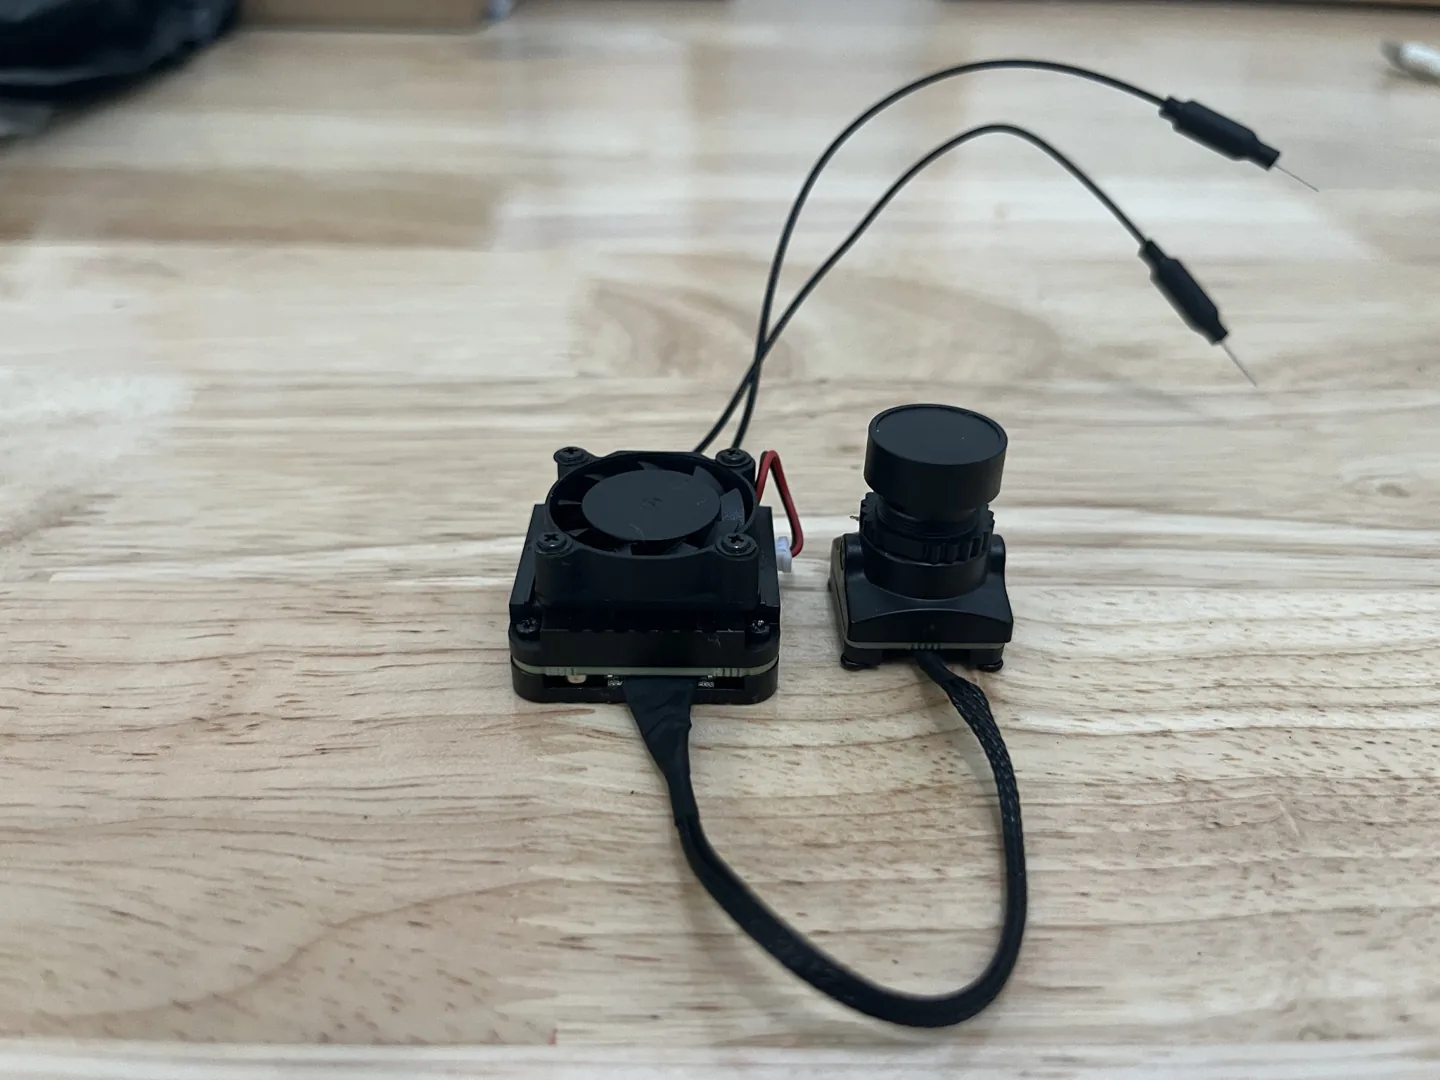
A compact fan-cooled transmitter module connected to a separate camera board. Presented with an SSC338Q-based reference configuration. Hardware and imaging combinations are confirmed when you request a sample.
From the supplied product specification, not an independent performance certification.
Reference engineering configuration with active cooling, modular camera and digital video capability.
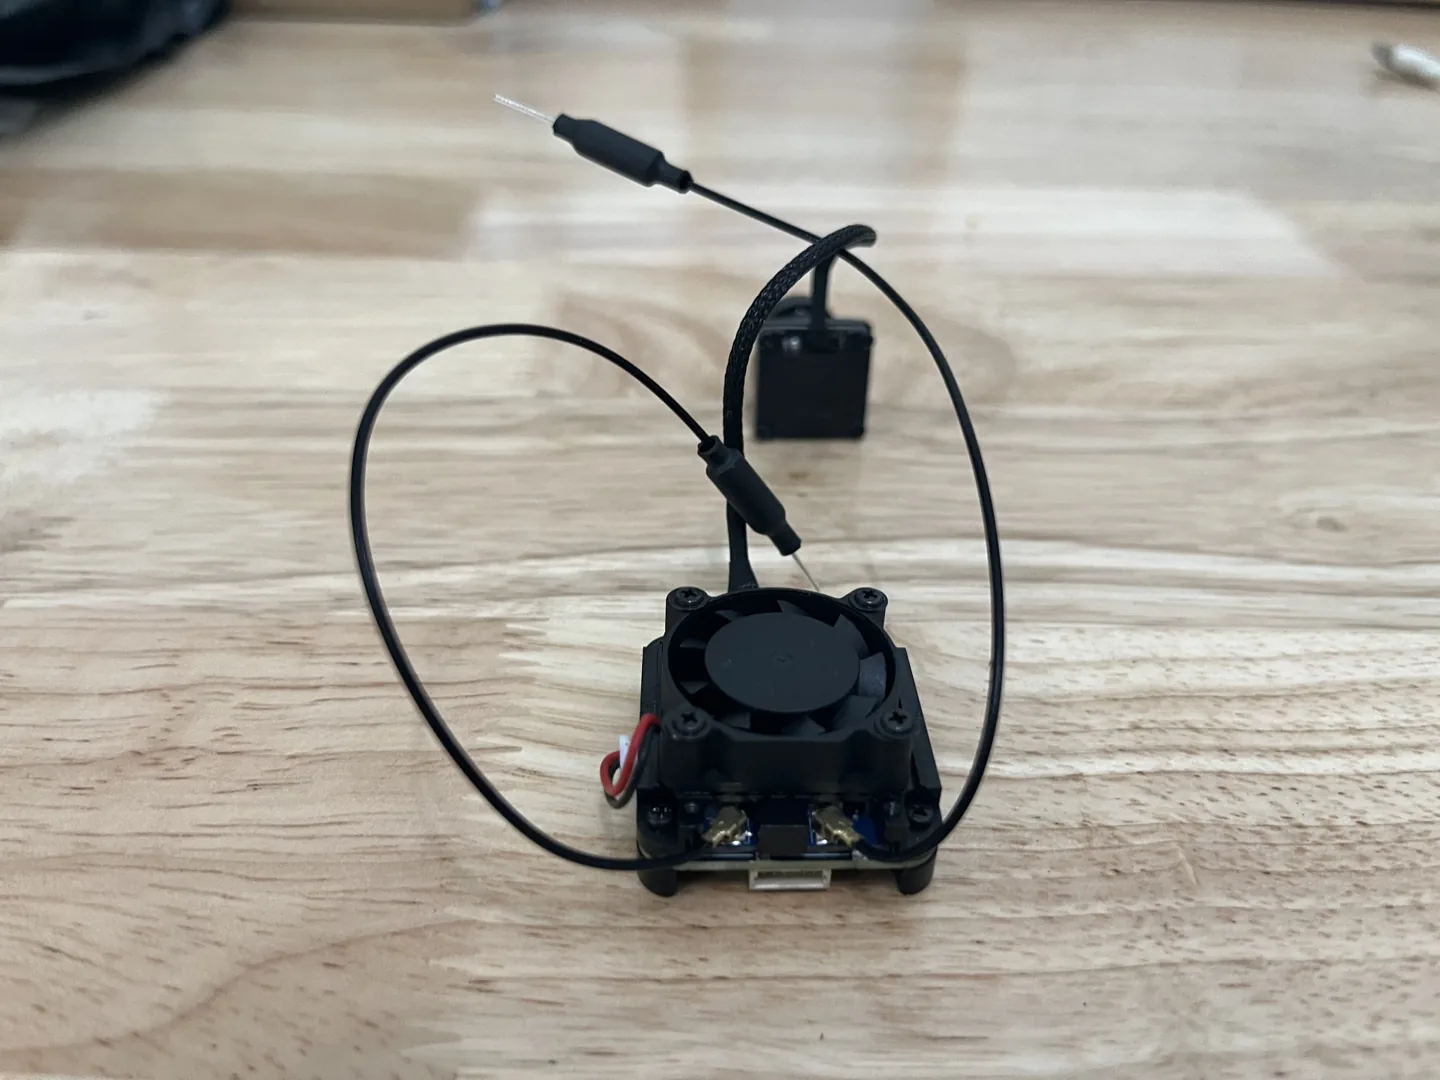
A visually similar second hardware sample is available; controller identification and performance table pending confirmation.
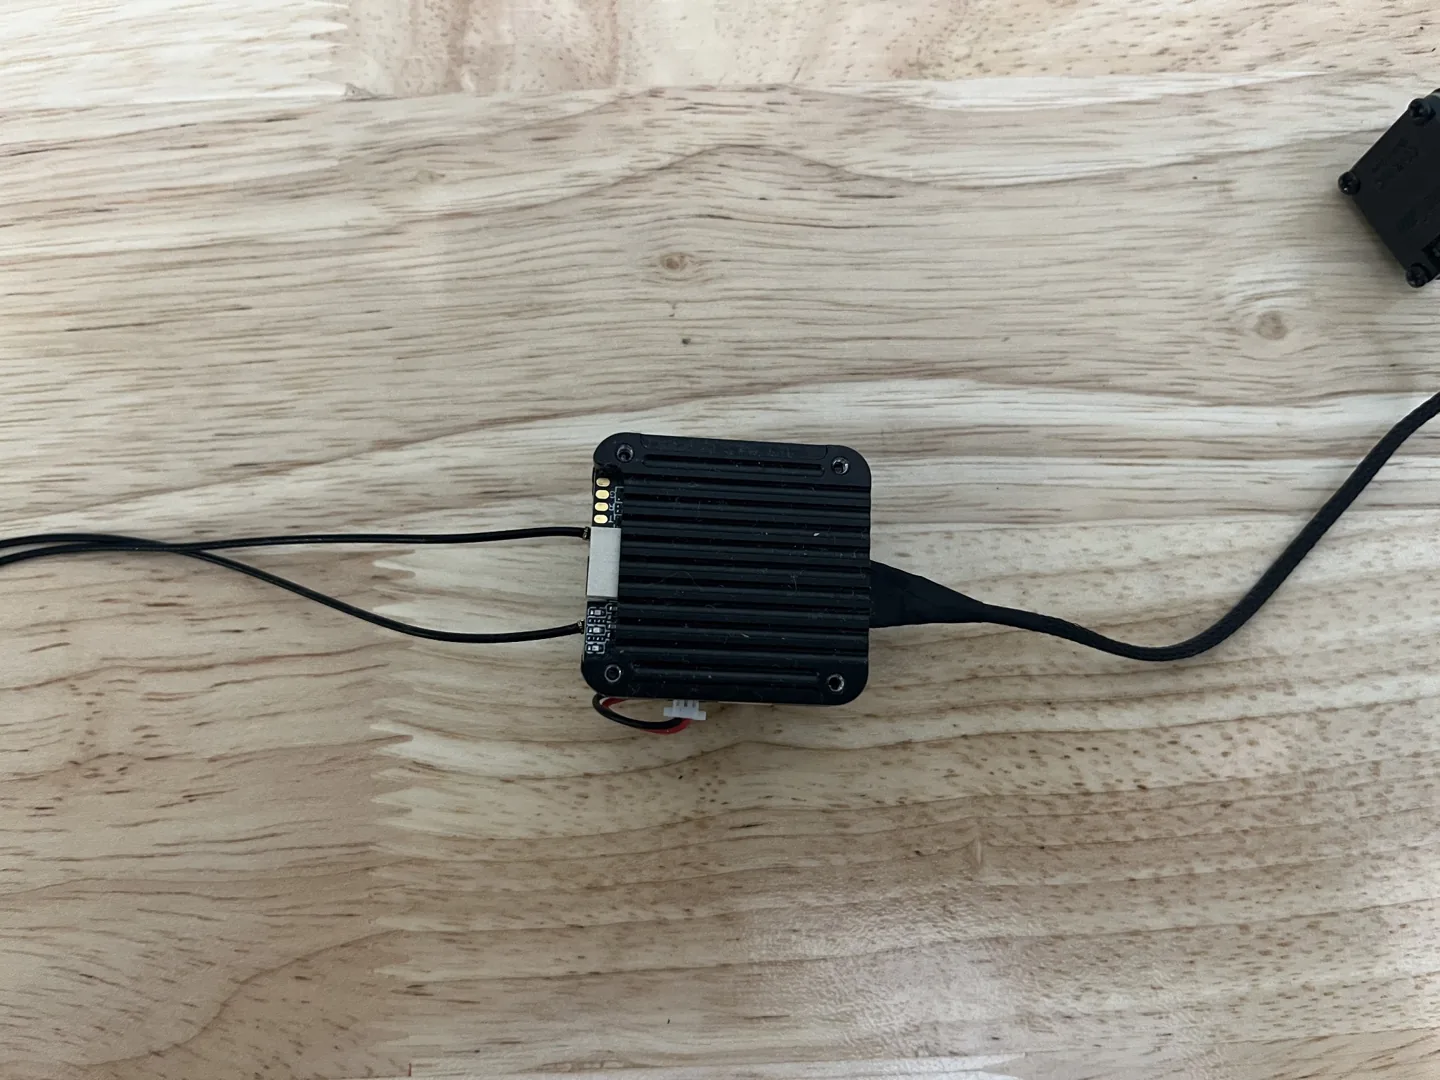
These photographs show the unit as supplied. The cleaned studio image in the hero is illustrative; the gallery is unretouched hardware evidence.
From the supplied product specification, not an independent performance certification.
From FPV prototypes to integrators evaluating camera and telemetry workflows.
Digital video platform for compact FPV builds and experimental aircraft.
An integration starting point for inspection and mission-specific UAV projects.
Camera-to-ground connectivity for mobile robotic platforms.
A configurable platform for prototyping, learning and comparative tests.
A transparent overview of the manufacturer-supplied reference sheet. Confirm the exact camera, software build and RF configuration before ordering.
Published parameters are transcribed from the supplied manufacturer document and are subject to configuration and verification. The stated 16 km unobstructed-range figure is not an independently verified guarantee and is deliberately excluded from headline claims. Regulatory requirements vary by country.
Start with a paid engineering sample, or discuss a tailored integration plan with the team.
Evaluate an assembled unit with camera and relevant accessories; configuration and shipping quoted individually.
Discuss board-level sourcing, camera options, harnesses and integration requirements.
Discuss OpenIPC integration, UART/MAVLink workflow, enclosures and project-specific changes.
Pin assignments, power warnings, interface diagrams and configuration notes in English and Chinese.
Review the documented hardware interfaces and the checks to make before integrating a video link into an aircraft or robotics platform.
Understand RX/TX crossover, shared power pins and the checks required before live telemetry integration.
MAVLink & UART wiring checklist →Compare camera, encoder, RF, power and firmware requirements before requesting an engineering sample.
Choosing an OpenIPC video module →A compact fan-cooled transmitter module connected to a separate camera board. Presented with an SSC338Q-based reference configuration. Hardware and imaging combinations are confirmed when you request a sample.
Explore MG880FM product details →Looking for paid evaluation units, an OEM option or custom development? Describe the application and the required configuration.
We review new inquiries and reply from [email protected].