Power and cooling
Check power polarity at the actual connector before connecting a battery. The documented input range is 9–22 V; a regulated supply and adequate current headroom are recommended. Keep the fan and heatsink airflow unobstructed.
SSC338Q reference configuration for FPV, UAV and embedded camera projects.
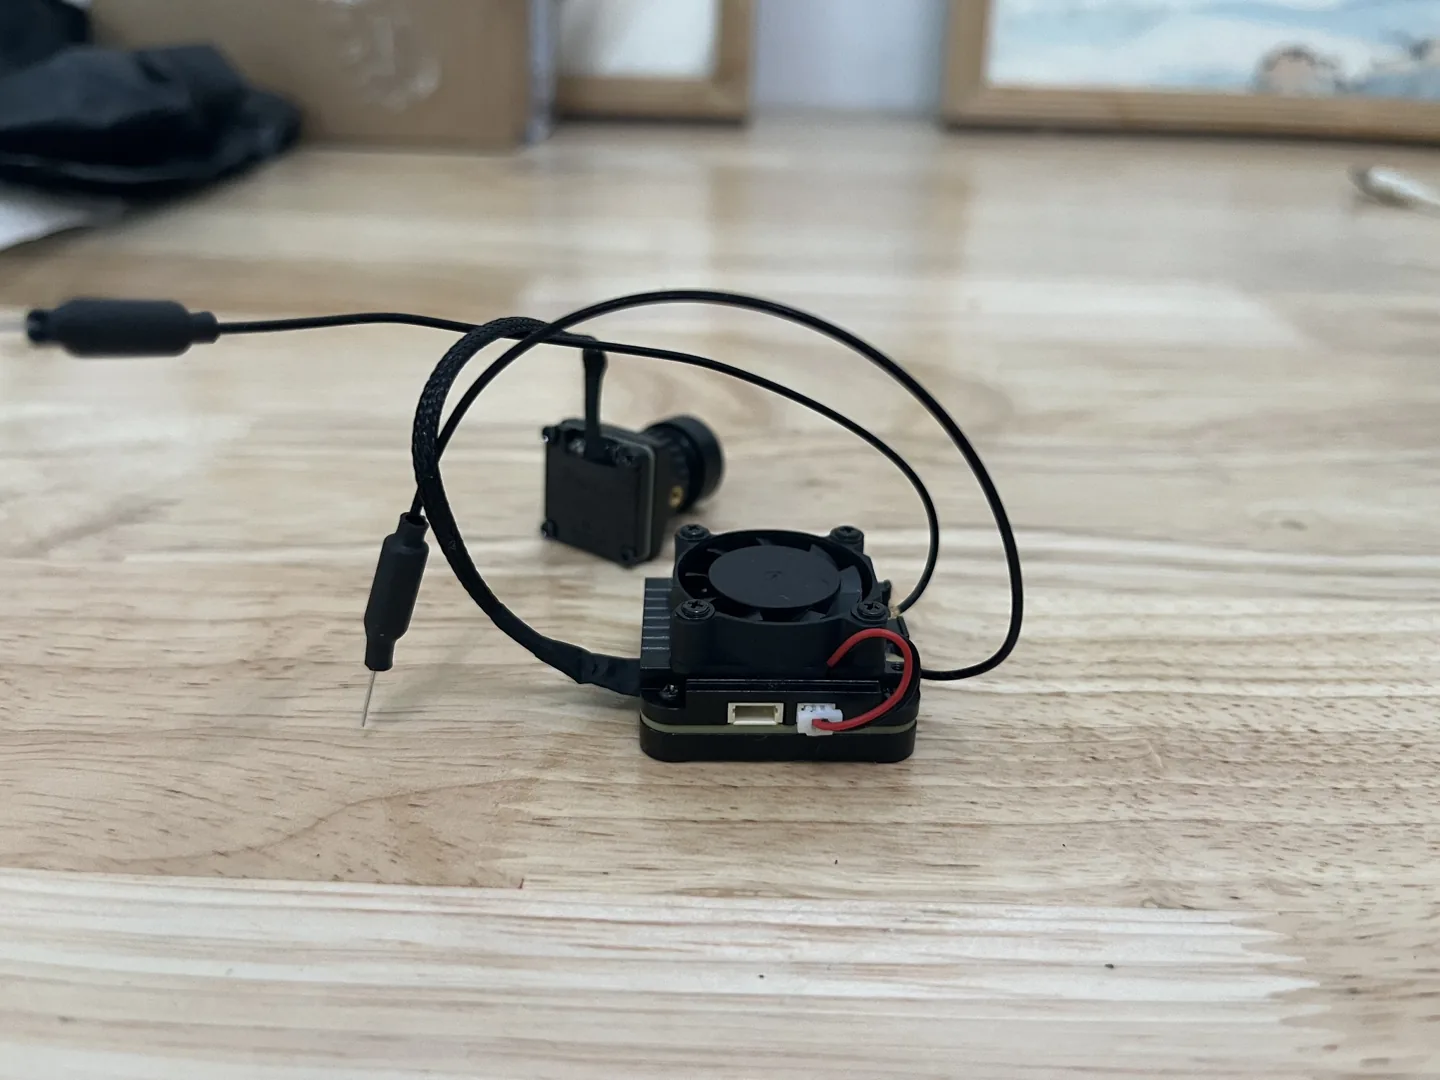
MG880FM combines a fan-cooled video transmitter mainboard with a separate M12 camera module. The published reference configuration uses an SSC338Q controller, OpenIPC firmware, dual 5.8 GHz IPEX antenna connectors and a shared six-pin power/UART interface. Exact SoC, sensor, antenna and firmware options must be confirmed for each supplied sample.
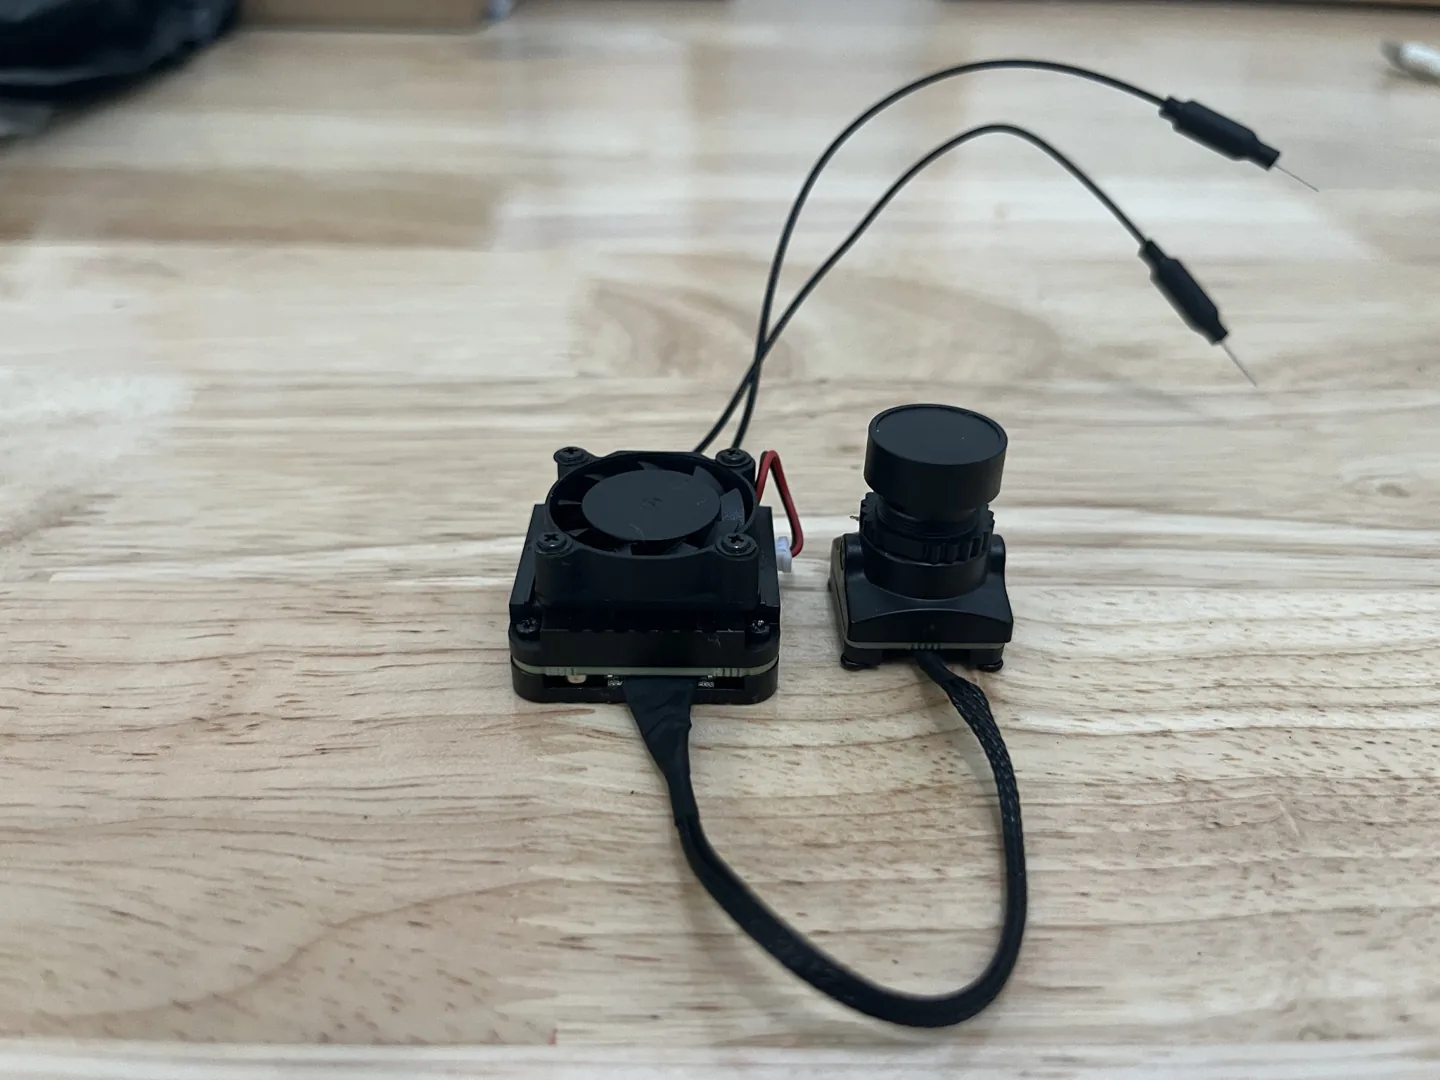
These are manufacturer-document values, not results of independent Telewoo qualification tests.
OpenIPC is a third-party open-source project. Product compatibility and radio permissions must be verified for the exact supplied configuration.
Check power polarity at the actual connector before connecting a battery. The documented input range is 9–22 V; a regulated supply and adequate current headroom are recommended. Keep the fan and heatsink airflow unobstructed.
The six-pin external harness shares power and UART lines. On the module, R is the RX input (connect to flight-controller TX) and T is the TX output (connect to flight-controller RX). A serial connection alone does not establish end-to-end bidirectional MAVLink; validate the installed firmware, ground-side routing, baud rate and link configuration.
Confirm the exact camera CMOS, M12 lens, MIPI ribbon orientation, antenna connector and radio configuration before purchasing. Frame-rate and encoding combinations depend on the selected image sensor and firmware build.
The supplied specification mentions a 16 km line-of-sight figure under favorable conditions. Telewoo has not independently established that range, end-to-end latency or field reliability. We therefore do not advertise a guaranteed range or latency. RF power and use of 5.8 GHz channels must comply with the regulations of the intended operating country; the document is not proof of CE/FCC certification.
Describe the target aircraft or robotic platform, sensor choice, camera orientation, antenna requirements, flight controller, desired telemetry workflow and sample quantity. The exact BOM, quote, delivery and test criteria can then be agreed.